

Pigeon® 2.0 IMU
Pigeon® 2.0 IMU
SKU:21-737785
In stock
Couldn't load pickup availability
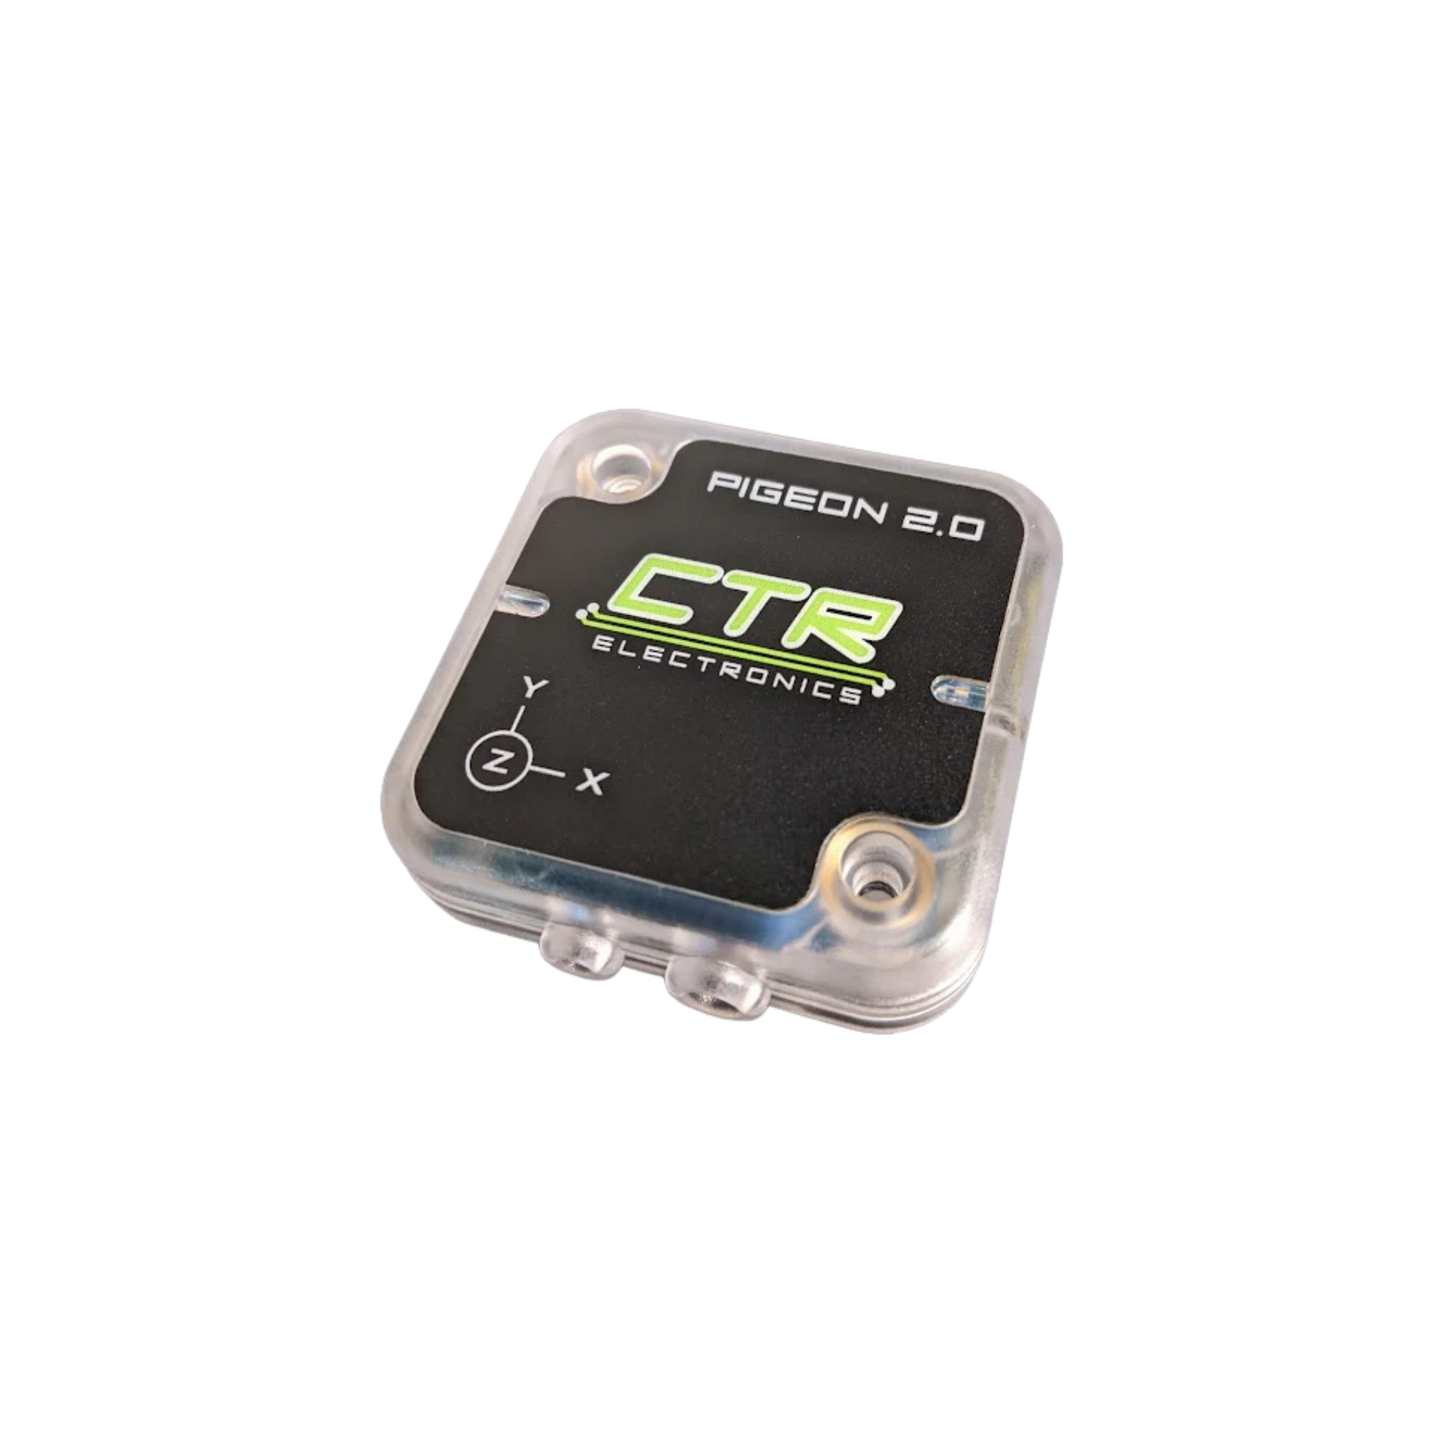
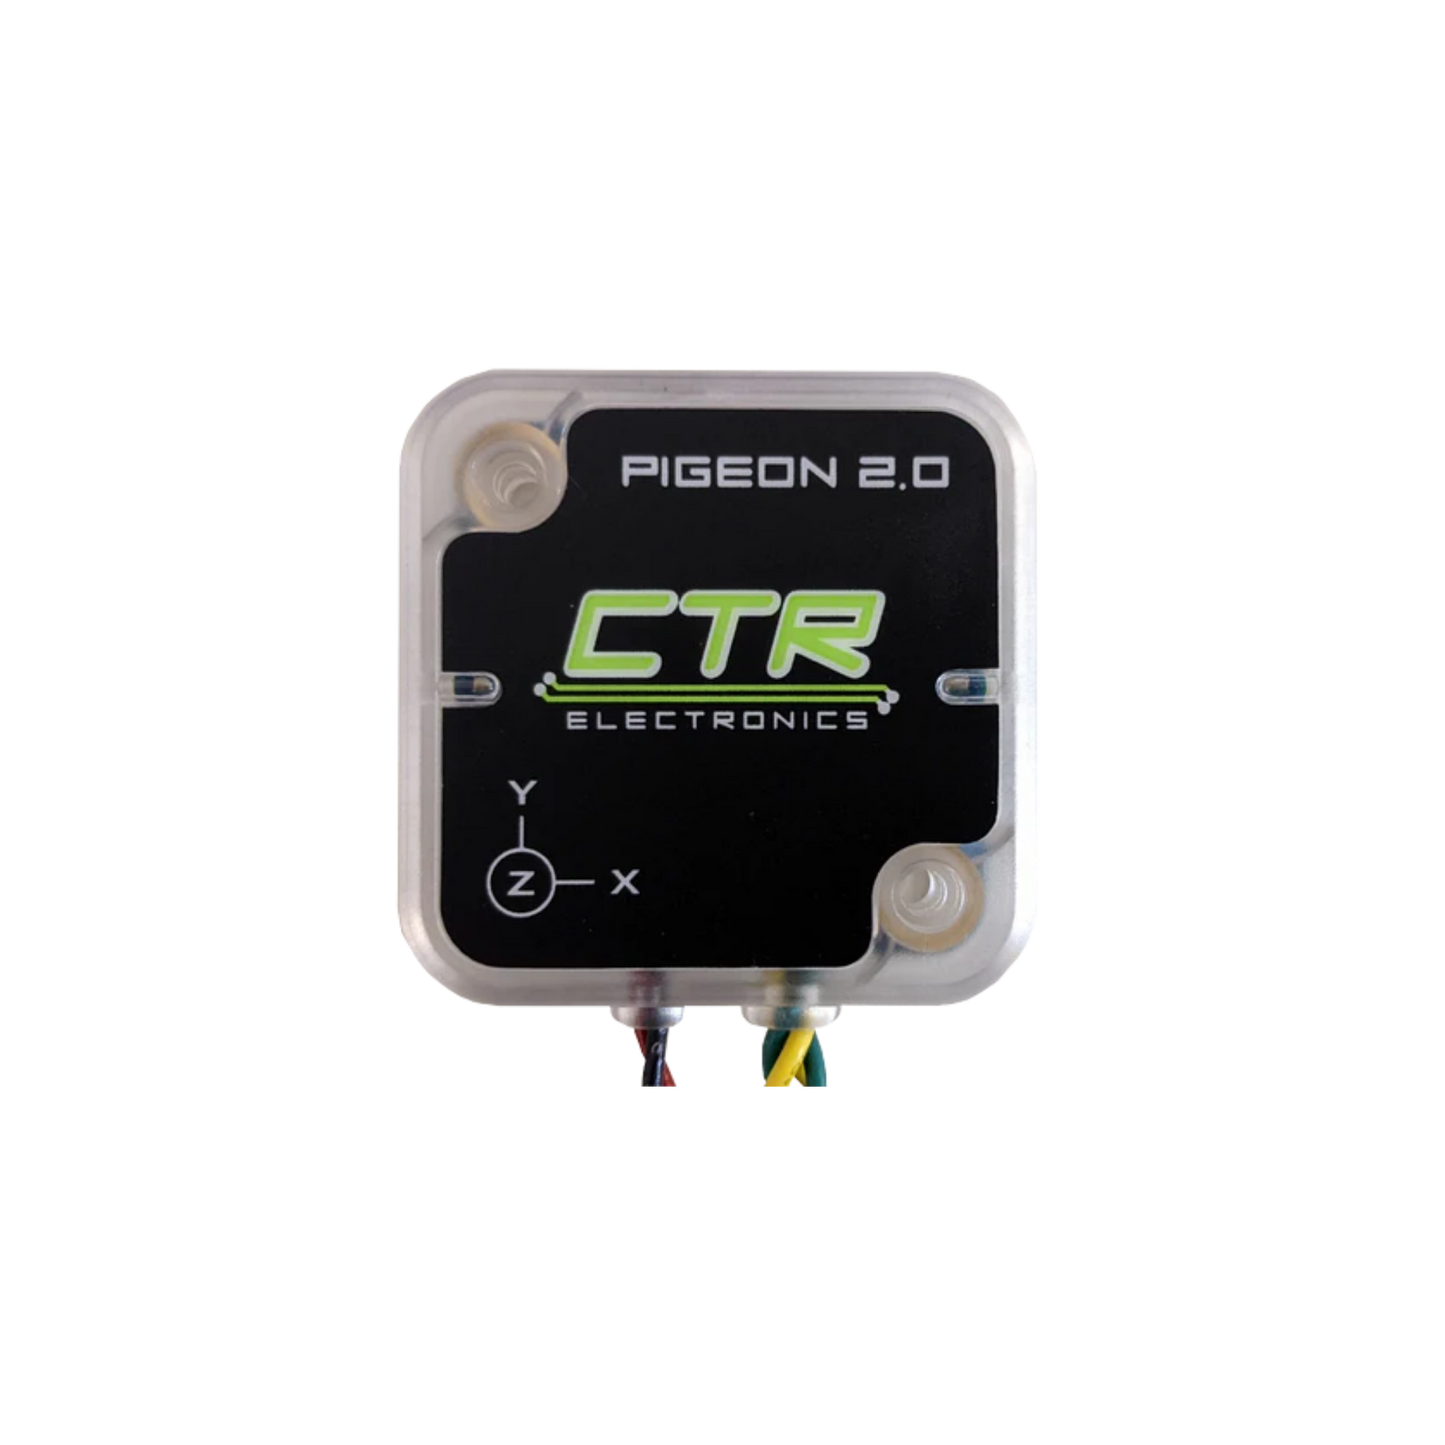
The Pigeon ® 2.0 is an all-in-one Inertial Measurement Unit (IMU) designed to give robotics teams and professionals rock-solid heading, orientation, and motion data without tedious bench setup. Featuring built-in 9-axis sensor fusion, factory-calibrated components, and massive improvements to gyro drift, it operates out of the box with zero required user calibration- meaning you can power up on the field and start driving immediately!
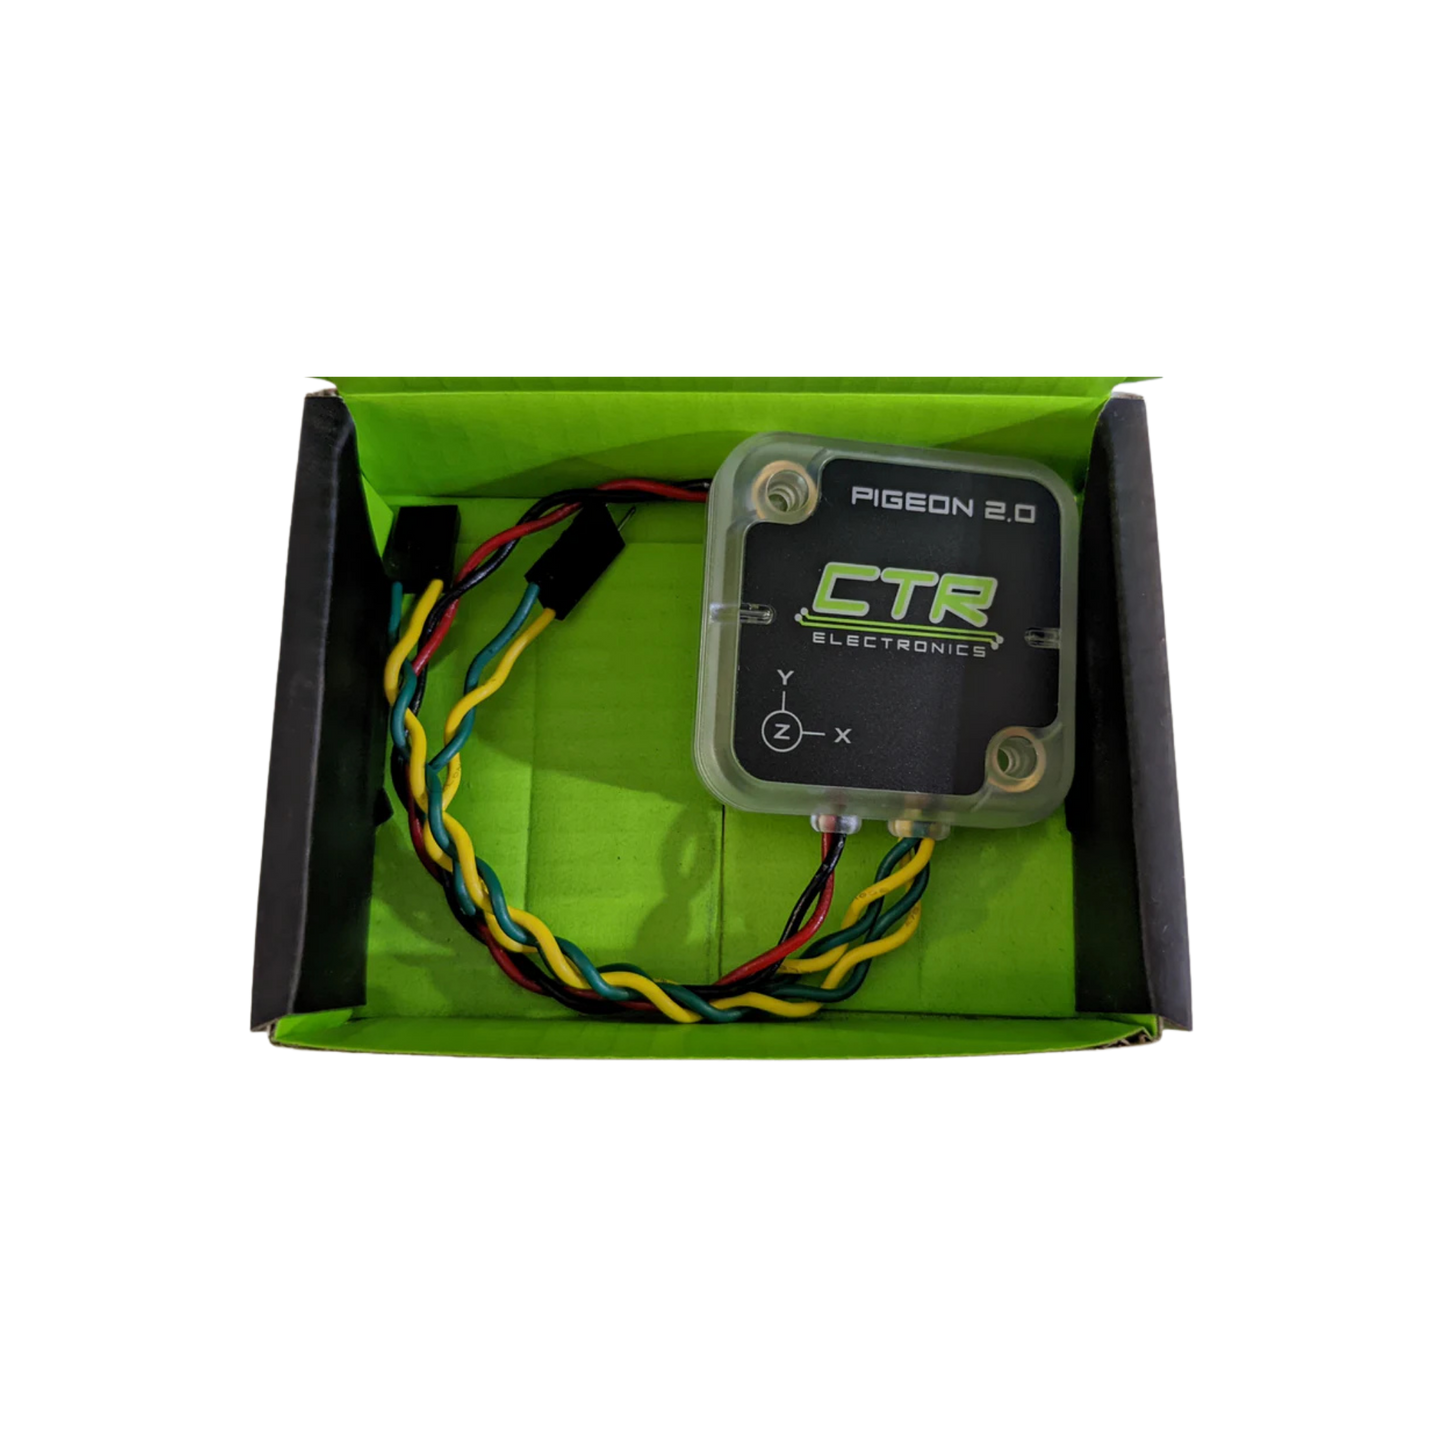
Encased in a protective polycarbonate case, the Pigeon ® 2.0 communicates natively over CAN or CAN FD, hooking into the CTRE ecosystem for fast software setup, live telemetry, and direct integration with Phoenix Tuner and Phoenix Pro.
- Zero-Calibration Boot: Power up and drive immediately. The Pigeon ® 2.0 doesn't require you to hold the robot still at power-on, nor does it demand temperature or on-boot calibration routines before giving you usable heading data.
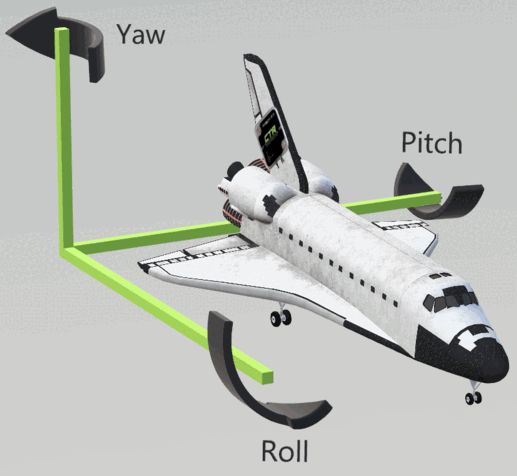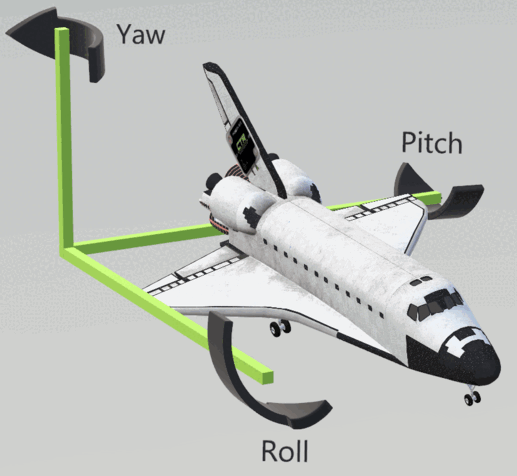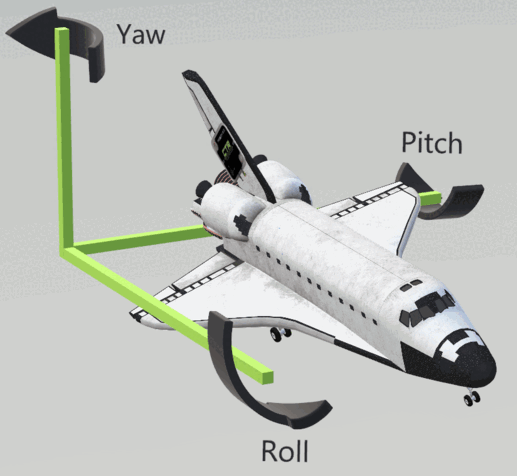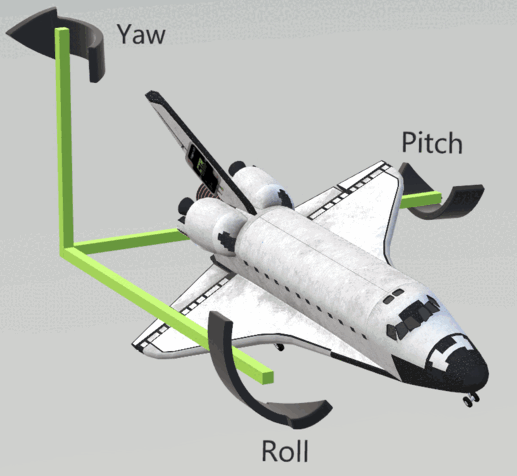
- Full 9-Axis AHRS Fusion: Combines a 3-axis gyro, 3-axis accelerometer, and 3-axis magnetometer through an internal Kalman filter to output precise Yaw, Pitch, Roll, Quaternions, and Gravity Vectors.
- Continuous Yaw & Auto-Rebiasing: Keeps heading measurements smooth across full 360-degree rotations. The gyro automatically re-biases itself whenever the device detects 4 seconds of stillness.
- Mount in Any Orientation: Hardware-level orientation independence lets you attach the housing flat, vertical, or angled without corrupting your spatial data (refer to manual for setup details).
- Factory Calibrated & Temperature Compensated: Accelerometer, gyro, and temperature-sensitive components are fully calibrated at the factory, protecting your control loops against thermal drift in long matches.
- Dual CAN / CAN FD Support: Connects directly into your CAN network with dual lead-pairs for simple daisy chaining. Fully compatible with both roboRIO and CANivore setups.
- Rugged, Flexible Power: Operates across a wide 6V to 28V input range with built-in reverse power protection and an enclosed polycarbonate housing to keep field debris off internal circuitry.
- Wireless Configuration & Simulation: Wirelessly flash firmware, adjust configs, and run diagnostics using Phoenix Tuner over roboRIO Wi-Fi. Features full hardware simulation support and software API binaries hosted on a 99.9% reliable Maven server.
Technical Specifications
- Internal Sensors: 3-Axis Accelerometer, 3-Axis Gyroscope, 3-Axis Magnetometer (9 DoF)
- Outputs: Yaw, Pitch, Roll, Quaternions, Gravity Vector
- Input Voltage Range: 6V to 28V DC
- Bus Support: CAN Bus and CAN FD (Compatible with roboRIO and CANivore)
- Circuit Protection: Reverse Input Power Protection
- Enclosure: Enclosed Polycarbonate Shell
- Wiring: 1x Power Lead-Pair, 2x CAN Lead-Pairs (3-pin male and female connectors)
- Firmware & API: Phoenix 6 / Phoenix Pro support, Phoenix Tuner wireless management, Hardware Simulation support
Field-Ready Motion Tracking
Eliminate the risk of ruined autonomous runs caused by accidental bumps during boot-up or uncalibrated gyros. The Pigeon ® 2.0 offloads heavy onboard sensor fusion math from your primary processor while giving your code smooth, low-drift heading data straight out of the pit.
(Note: The latest Pigeon ® 2.0 hardware update requires updating your software suite to the current release version.)
TIP: Pigeon ® 2.0 can be used with Phoenix Pro!
Yaw Drift
| During No Motion | ~0.12 degrees per hour |
| During Motion (with 4 second no-motion after boot-up) | ~0.4 degrees per minute |
| During Motion (instantly after boot-up) | ~1.0 degree per minute |
Technical Specifications
See Hardware User Manual for full specifications.
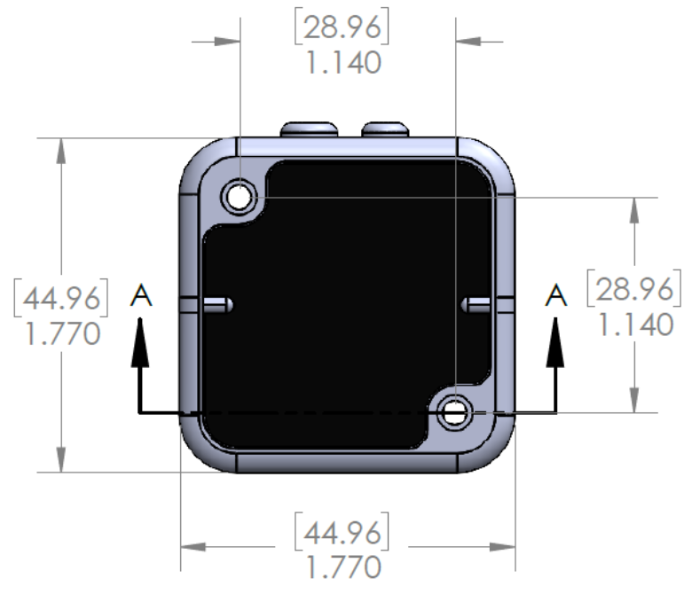
| Weight | 1.07 ounces (30.39g) |
| Nominal Input Voltage | 12 Volts |
| Min/Max Voltage Range | 6V - 28V |
| Typ. Current Draw @12V | 40mA |
| Typ. Current Draw @28V | 21mA |
| Gyroscope Range (dps) | 125 - 2000 |
| Gyroscope Resolution | 16 bits |
| Accelerometer Range | +/- 8g |
| Accelerometer Resolution | 16 bits |
| Magnetometer Range | +/- 1150 uT |
| Magnetometer Resolution | 0.3 uT |
| Compass Accuracy (with Cal) | ~1 degree |